Volume
1.volume的优化
- 1.volume的压缩对版本迭代,储存都是很有必要的
- eg:一块面发射烟,我们可以把他分层3套弄,既远中近
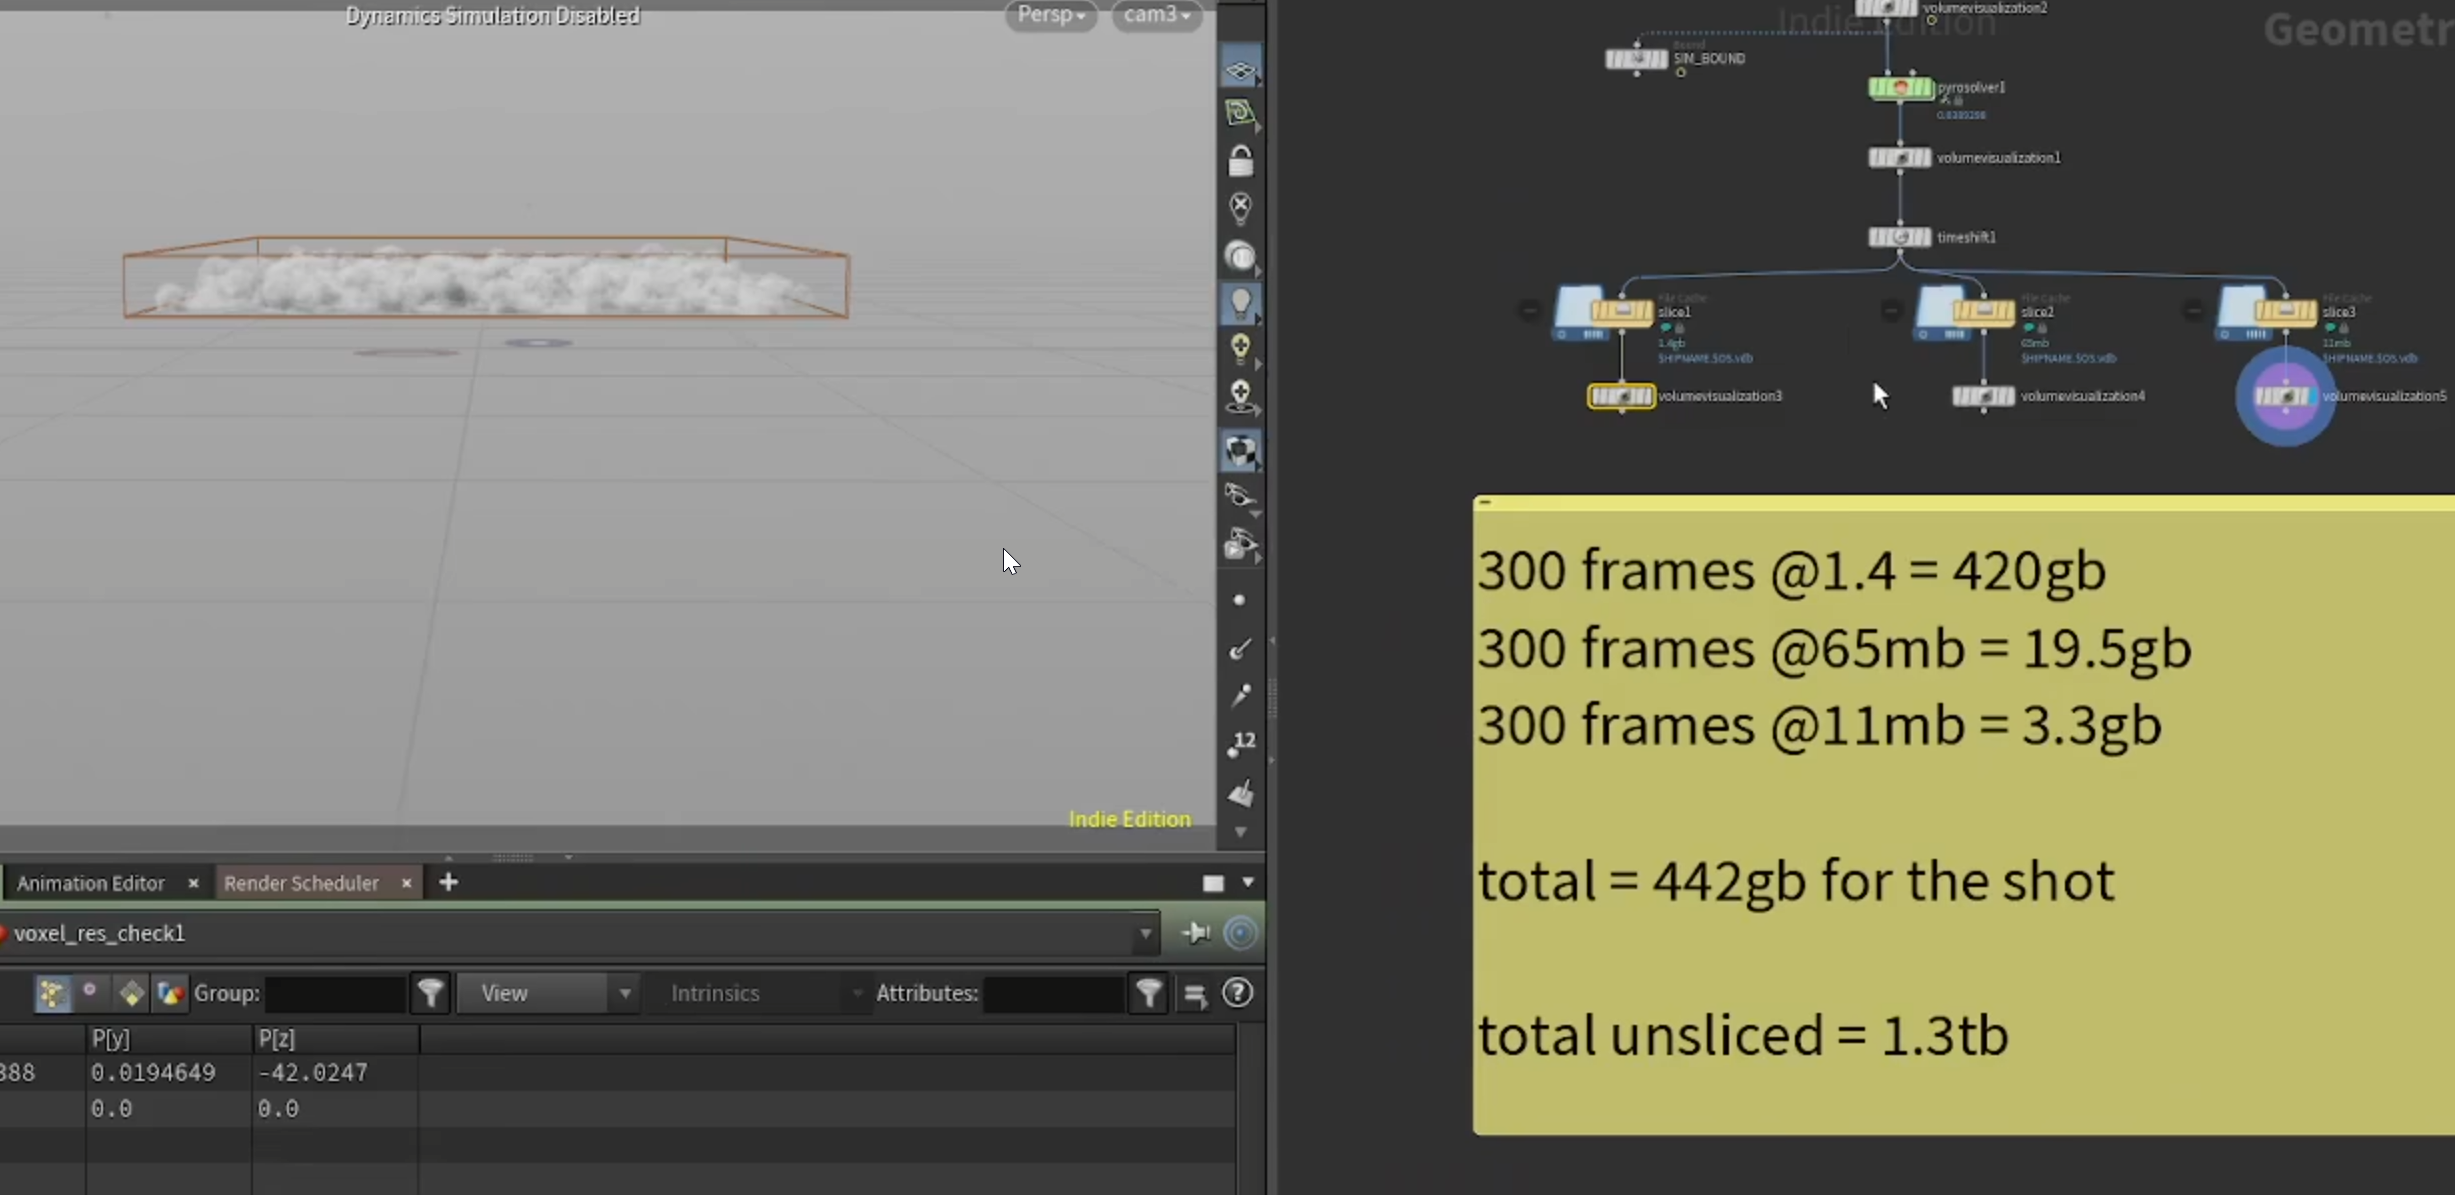
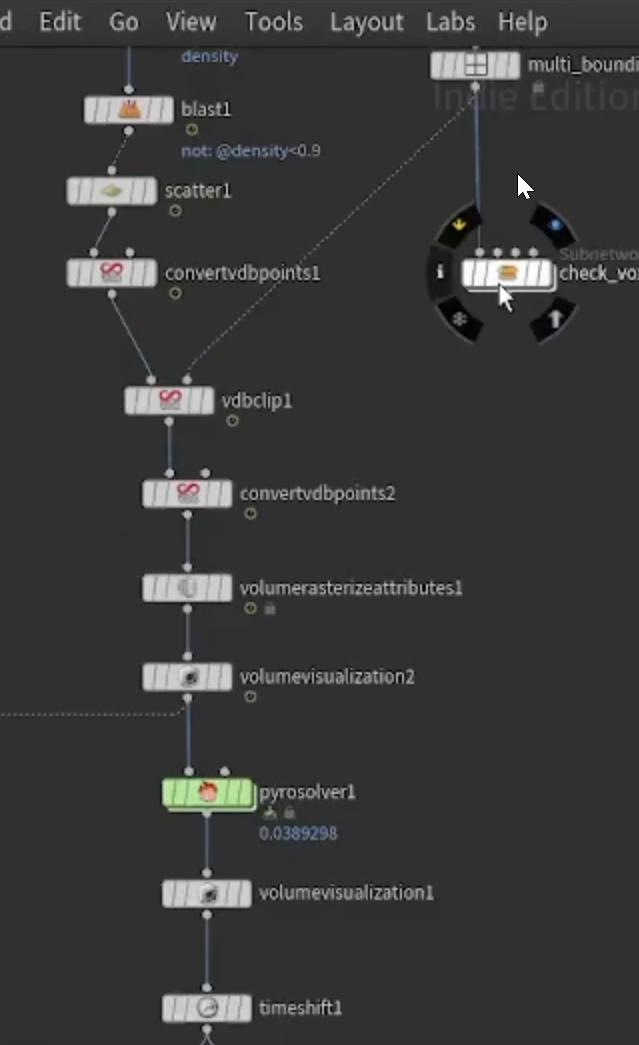
- 可以用multi_bounding_box工具分开(需要搭配bound用)
- 2.优化数据储存
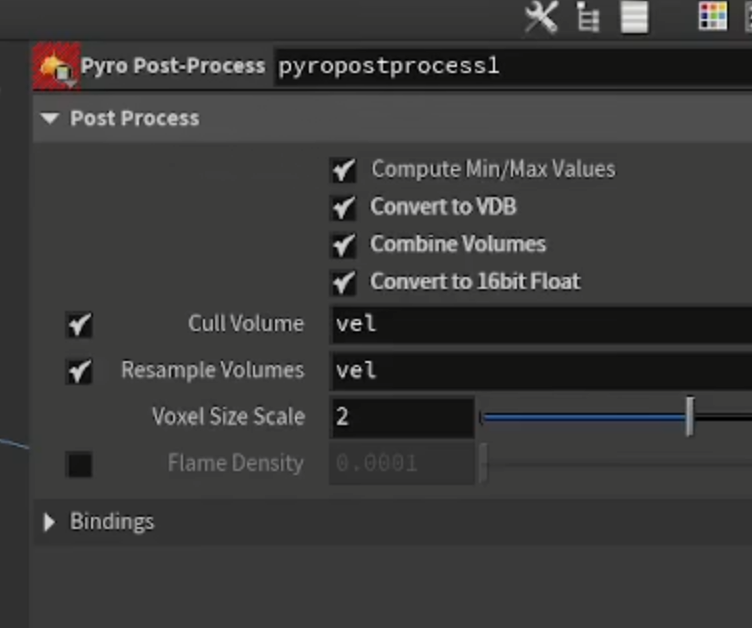
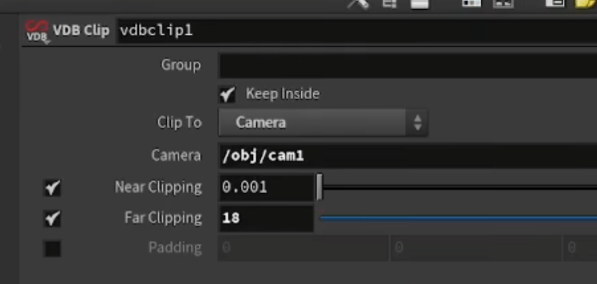
- 3.后期通过cam裁切体素
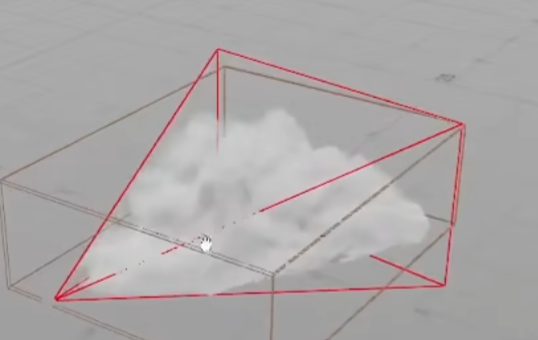
- 4.解算中裁切
- 注意是gaswrangle
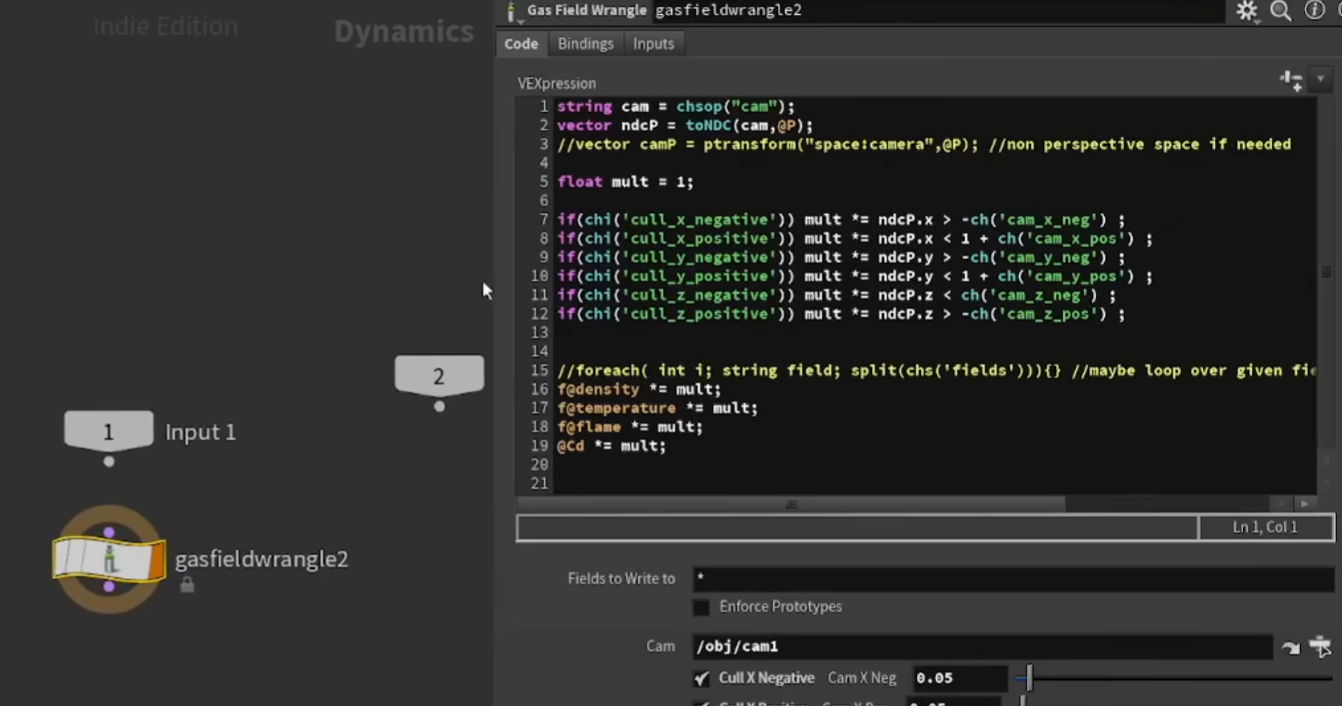
- python
string cam=chsop("can");
vector ndcP=toNDC(cam,@P);
float mult =1;
if(chi('cull_x_negative')) mult *=ndcP.x> -ch('cam_x_neg');
if(chi('cull_x_positive')) mult *=ndcP.x< 1+ch('cam_x_pos');
if(chi('cull_y_negative')) mult *=ndcP.y> -ch('cam_y_neg');
if(chi('cull_y_positive')) mult *=ndcP.y< 1+ch('cam_y_pos');
if(chi('cull_z_negative')) mult *=ndcP.z> ch('cam_z_neg');
if(chi('cull_z_positive')) mult *=ndcP.z< -ch('cam_z_pos');
f@density*=mult;
f@temperature*=mult;
f@flame =mult;
f@Cd=mult;
2.volumeSample && volumeGradient
- 1.volumeSample
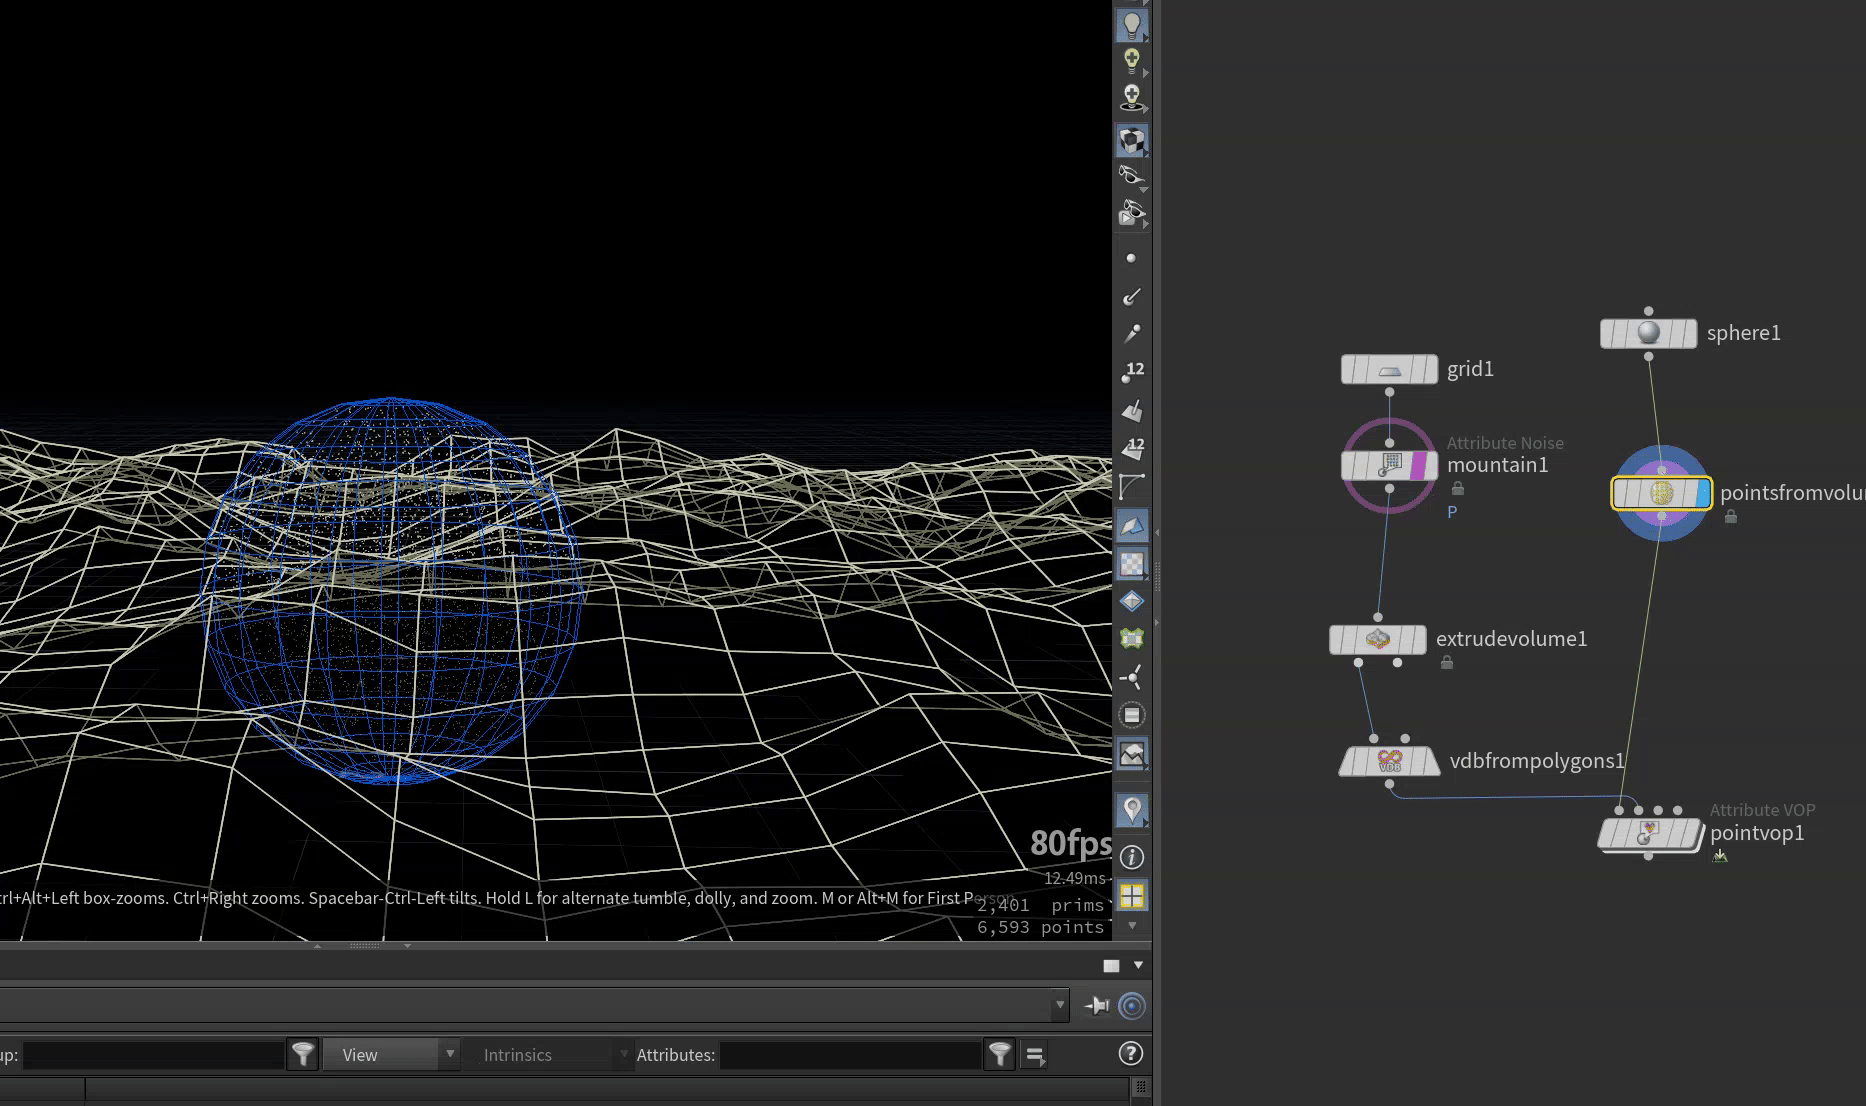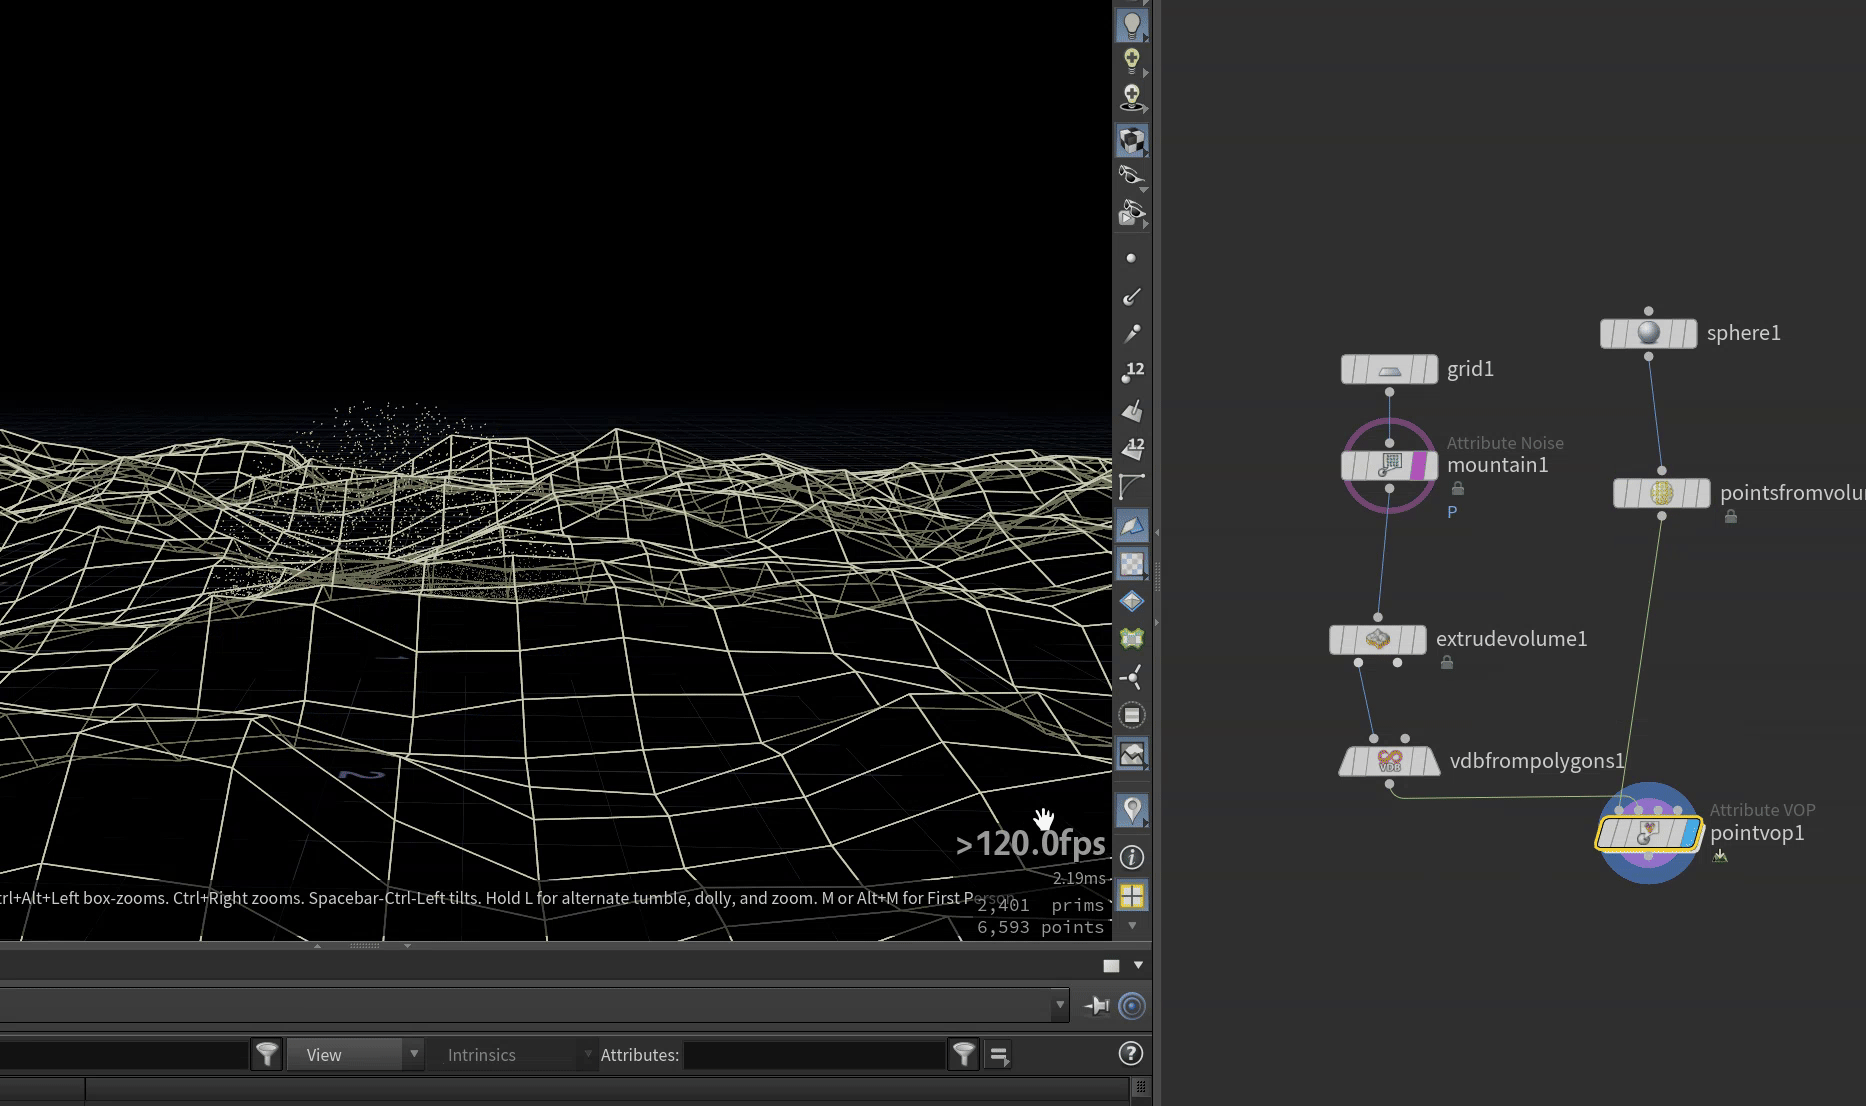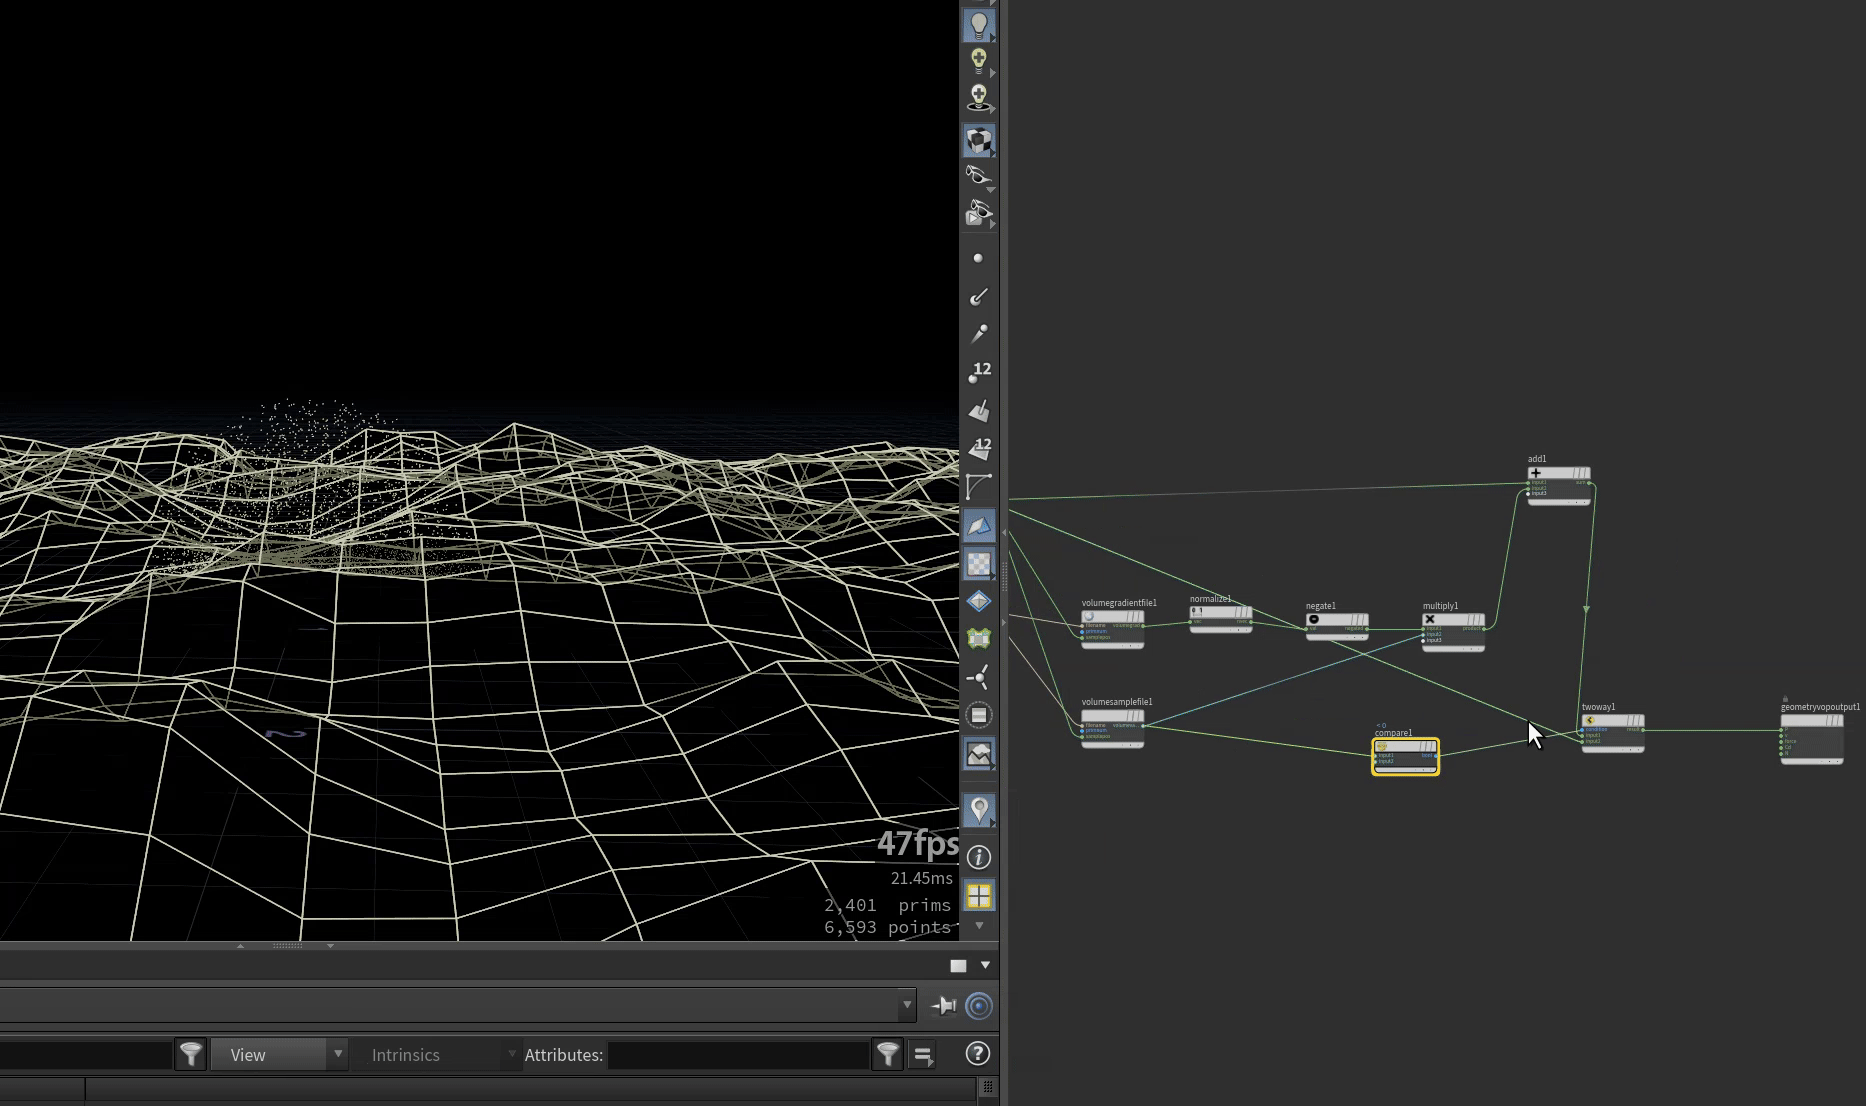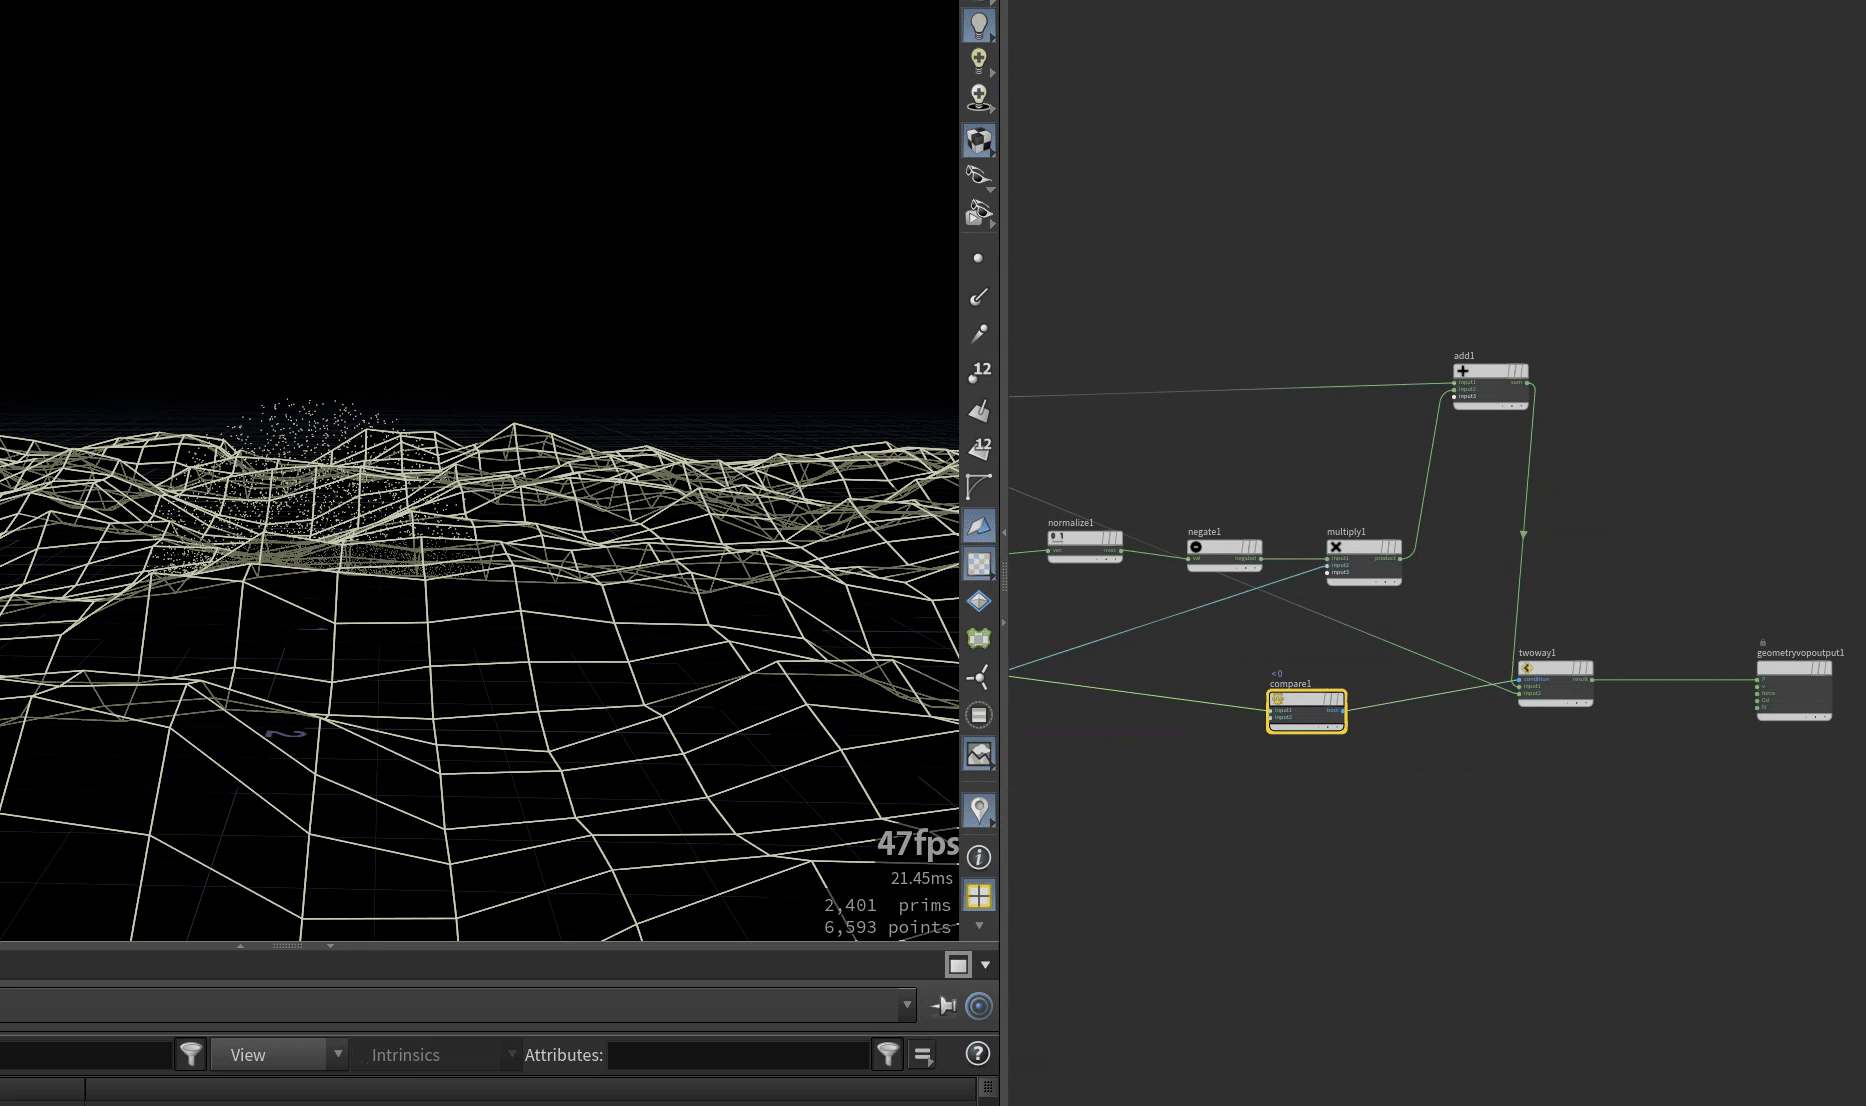
- exp: 判断点是否在体积内
- vex :f@a=volumesample(1,'density',v@P);这里1和density对应的
- vop:volumesamplefile
- 实战:修改粒子穿插
3.class
1.Pyro_fire
pyrosolver_sparse:
- advection-reflection 中选项表示结算质量高低
- Double—Proj 0湍流更加直-1更加弯曲(细节多)(方向更加不稳定)
- turb >>>>> Pulse Len湍流停留时间长短
- collision >>>>iop iteration 碰撞迭代作用(迭代太低烟雾容易被吃掉,导致细节减少 可以提高3-5)
collision 碰撞设置
- volume source>>>scalar collision//collison -1 vector v//collisionvel
假影响光,思路
- 发光物>>scatter属性传递过去>>vdbformparticle>>vdbconvert(volume)
- 大致意思就是模糊发光物传递到物体上,在材质里调佣数据 做个颜色